Product Direction
FlowEdge is the boundary between a trained policy and robot control: convert once, fixed RSS, a period, a replayable action. Hardware runs the loop. FlowEdge runs the native head. LeRobot (or your stack) trains, encodes observations, and owns e-stop.
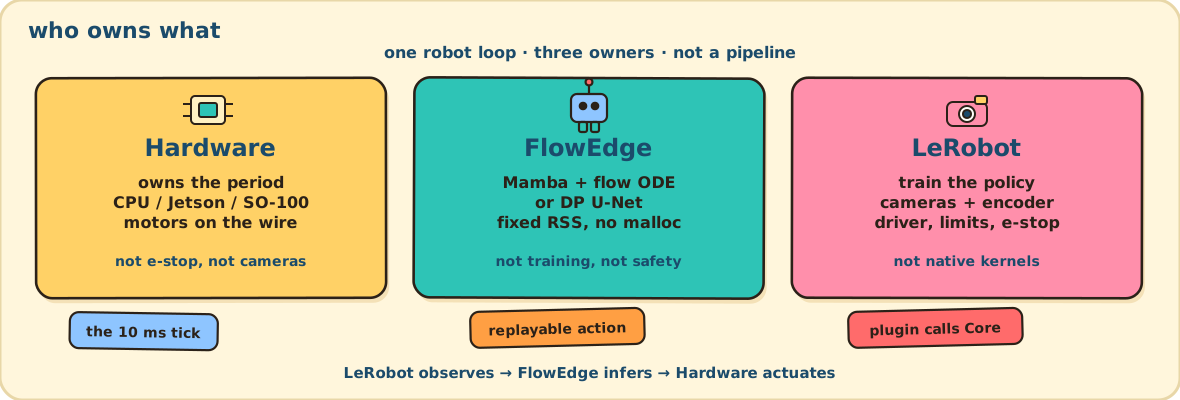
Keep |
Leave |
|---|---|
Hardware: CPU now; Jetson/ARM via plugin; CUDA Mamba, flow, and DP heads; matched GPU replay (#163) and CUDA Core period loop (#164) on GTX 1650 |
Robot e-stop and joint limits |
FlowEdge: flow matching, DP U-Net, Transformer decoder fixture, optional Relay |
Training, datasets, graph compilers |
LeRobot: plugin, encoders, drivers |
Native kernels and the arena |
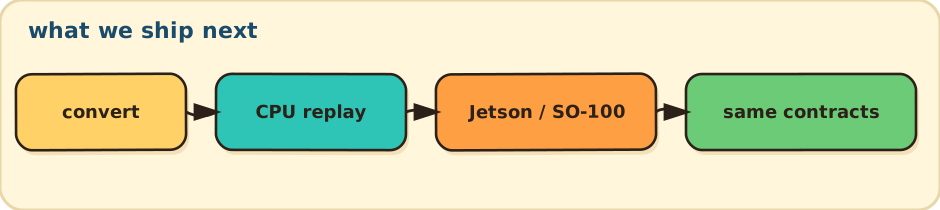
The sequence is convert → matched CPU replay vs PyTorch → Transformer fixture (#10) → CUDA device-resident flow (#161) and DP (#162) → matched GPU replay (#163) → CUDA DP conv occupancy (#174, #176, #179) → a period loop on Jetson or SO-100 with miss counts. Tenstorrent stays behind that GPU evidence. Success is an external team doing that without FlowEdge training code.