Action delivery
Use ActionDeliveryGate between Relay output and the controller.
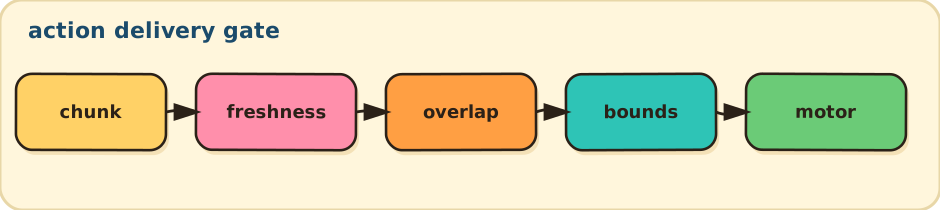
Input |
Gate behavior |
|---|---|
New generation |
Accept or replace the active chunk |
Old generation/sequence |
Reject as stale |
Different session/model |
Reject |
Late chunk or old observation |
Reject as expired |
Unsafe value |
Reject the chunk or clamp each control step |
Missed control tick |
Skip obsolete steps by timestamp |
auto gate = fe::relay::ActionDeliveryGate::create(
    model,
    {.control_dim = 7,
     .overlap_steps = 2,
     .step_period_ns = 10'000'000,
     .max_source_age_ns = 80'000'000,
     .unsafe_policy = fe::relay::UnsafeActionPolicy::kClamp},
    {.lower = lower, .upper = upper, .max_delta_per_step = max_delta});

gate->accept(action_message, now_ns);
if (auto step = gate->next(now_ns))
  controller.write(step->values);
action_dim is the flattened chunk size: step_count × control_dim. Setup copies limits once;
accept, replacement, overlap, and next allocate nothing. Run action_delivery_sample for a
25 Hz policy feeding a 100 Hz controller.
This is a deterministic software gate, not a certified robot safety controller. Hardware limits, watchdogs, and emergency stops remain downstream.