Getting Started
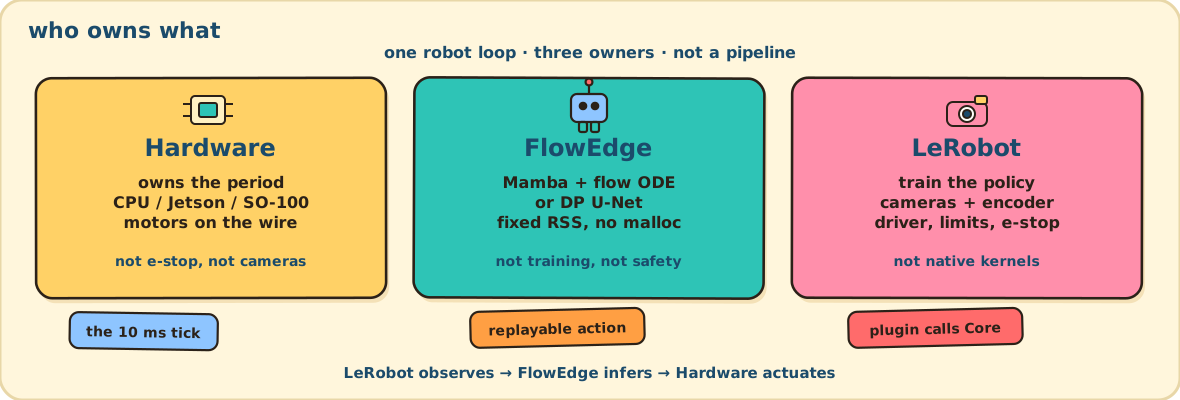
FlowEdge is the deploy runtime, not the trainer. Convert a checkpoint, load it once, sample flow matching or Diffusion Policy. Optional Relay sits between processes when perception and control are split.
Goal |
Continue at |
|---|---|
Python wheel (CPU) |
|
Included flow-matching policy |
|
Diffusion Policy on Jetson / SO-100 / sim |
|
Your encoder, our flow or DP head |
|
Local IPC |
|
Cached SmolVLA expert (not a product head) |
|
Flow matching vs Diffusion Policy vs PyTorch |
GPT-2 conversion is a kernel incubator, not a product path.
Install (CPU wheel)
Download the wheel for your platform from the v0.1.2 Release assets. Filenames are flowedge-0.1.2-*. PyPI is not published.
Those wheels are CPU; CUDA needs nvcc (CUDA).
python -m pip install flowedge-0.1.2-*.whl
mkdir -p models
curl -L "https://huggingface.co/ReForceMind/mamba_flow/resolve/main/mamba_flow.safetensors" \
  -o models/mamba_flow.safetensors
python examples/core/flow_sample.py models/mamba_flow.safetensors euler 10
Full Python API: Python.
From source
CMake 3.21+ and C++23. CI uses LLVM/Clang 23; GCC 13+ is supported.
git clone https://github.com/reforcemind/FlowEdge.git
cd FlowEdge
cmake -B build -DCMAKE_BUILD_TYPE=Release
cmake --build build --config Release -j
FLOWEDGE_BACKEND=cuda needs nvcc (WSL or MSVC on Windows) and tries to keep
Mamba, flow, and Diffusion Policy heads on device. A 4 GB card that cannot
allocate the U-Net falls back to CPU kernels instead of failing load. Check
Engine.cuda_resident. CUDA.
Get a model
mkdir -p models
wget -qO models/mamba_flow.safetensors \
  "https://huggingface.co/ReForceMind/mamba_flow/resolve/main/mamba_flow.safetensors"
LeRobot: python -m flowedge_dev pipeline convert (converter).
Sample an action
./build/flow_sample models/mamba_flow.safetensors euler 10
Solver is euler, heun, or rk4. Last argument is NFE (how many velocity-net evaluations). That is the cost of flow matching: a short ODE, not a long denoiser. The published gate is ULP vs PyTorch (~1e-6 rel), not a policy p50.
Converted Diffusion Policy — plugin owns the LeRobot processor; Core owns the U-Net:
python -m pip install -e integrations/lerobot
python -m flowedge_dev pipeline rollout models/diffusion_pusht.flowedge.safetensors \
  --steps 10 --period-ms 10 --on-miss hold
--on-miss: hold last sent action, drop the send, or raise. Limits and e-stop stay in the robot adapter. Jetson: scripts/edge_dp_rollout.sh. A 10 ms period on current PushT DDIM is a miss log, not a hit-rate claim (performance).
Use an external encoder
Keep ResNet / VLM / your own encoder where it already runs. Pass the condition vector in; FlowEdge only integrates the head.
./build/external_flow_sample models/mamba_flow.safetensors
./build/streaming_snapshot models/mamba_flow.safetensors
Caller owns condition, noise, and output. Engine owns solver scratch.
Relay
Optional local IPC when perception and control are separate processes. Matched DP replay does not start Relay.
cmake -S . -B build-relay -DCMAKE_BUILD_TYPE=Release -DFLOWEDGE_RELAY=ON
cmake --build build-relay -j
FLOWEDGE_BUILD_DIR="$PWD/build-relay" ./scripts/relay_demo.sh models/mamba_flow.safetensors